Teaching & Mentoring
I have taught robotics, design, and manufacturing courses at Purdue University and HKUST since 2020, and have mentored undergraduate and graduate researchers in the MARS Lab.
Teaching philosophy
Robotics is learned by building. Students understand an algorithm when they watch it drive real hardware, and they understand a sensor when they see it respond to the world. My courses pair foundational theory with laboratory work on physical systems, so that noise, calibration, timing, and tolerances become part of the lesson rather than an afterthought.
I aim to develop the judgment and communication skills students need for research and industry, and to run classrooms and labs where students from every background can experiment, ask questions, and learn from failure.
Teaching experience
IE 574: Industrial Robotics and Flexible Assembly
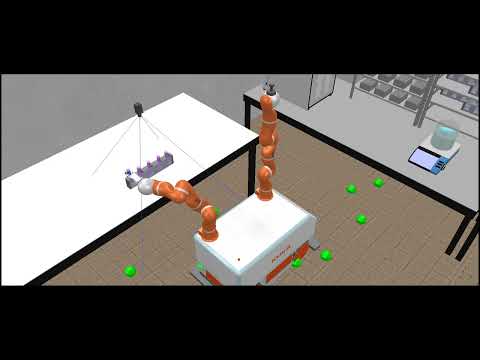
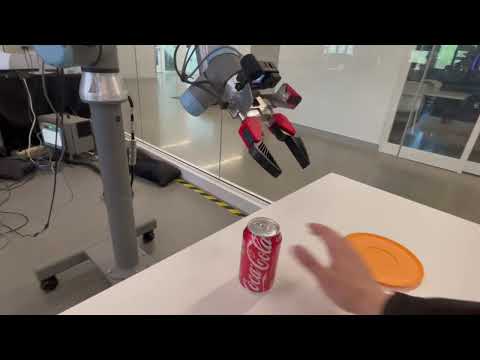
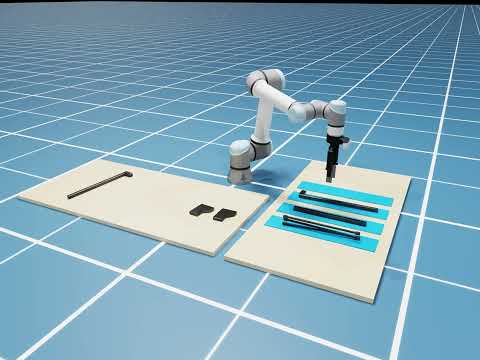
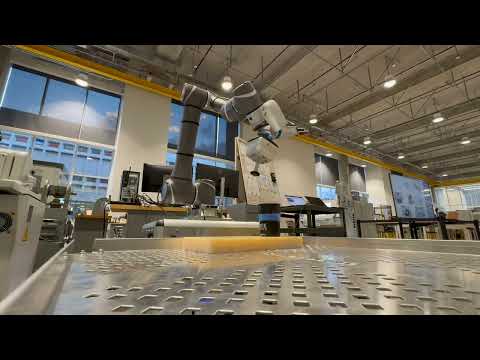
2022 — 2025Graduate Teaching Assistant · Purdue UniversityLed robotics and perception laboratories using CoppeliaSim, TMFlow, Python APIs, and FetchCore. Guided student teams on real-time object detection, visual servoing, and multi-robot coordination.
IE 370: Manufacturing Processes
PurdueGraduate Teaching Assistant · Purdue UniversitySupported instruction in traditional and advanced manufacturing methods. Led weekly laboratory sessions and provided individual student support.
IE 472: Imagine, Model, and Make
PurdueGraduate Teaching Assistant · Purdue UniversityTaught 3ds Max for 3D design, rendering, and animation. Supervised project-based learning and evaluated final design submissions.
Design and Manufacturing
2020 — 2021Graduate Teaching Assistant · Hong Kong University of Science and TechnologyInstructed SolidWorks for mechanical design, assembly modeling, and system-level CAD. Led project-based coursework in which student teams designed and built a complete go-kart assembly.
Research mentoring
In the MARS Lab at Purdue (2022–2026) I mentored undergraduate and master's students on tactile-sensor fabrication, robot experiments, perception pipelines, and scientific writing. Several are co-authors on the FibTac, VTAP Gripper, MVP-Tac, and underwater robot papers.
Student evaluations
IE 574: Industrial Robotics and Flexible Assembly, Purdue University
Student projects
Representative team projects from IE 574: perception and manipulation systems on industrial robots.
 Play video
 Play video
 Play video
 Play video
Courses prepared to teach
Core undergraduate: Dynamics and System Modeling · Control Systems · Mechatronics · Manufacturing Processes and Automation
Robotics: Introduction to Robotics and Robot Programming · Robot Perception and Sensing · Human–Robot Interaction
Graduate / special topics: Tactile Sensing for Robotic Manipulation · Multimodal Sensing and Embodied Intelligence · Soft and Bio-Inspired Robot Design