Postdoctoral Researcher · Robotics
Sheeraz Athar
Physical AI & Robotics (PAIR) Initiative ·
University of Notre Dame
Working with Prof. Nikolaus Correll on dexterous robotic hands
Working with Prof. Nikolaus Correll on dexterous robotic hands
📄 npj Robotics · Nature Portfolio · 2026
🏅 IROS 2026 Best Paper Finalist
🥈 ASME MRC 2nd Prize
NSF-funded
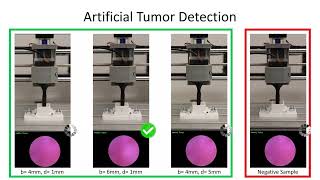
I design soft, compliant, and bio-inspired robotic systems with a focus on multimodal tactile sensing and physical interaction. My work spans soft robotics, underwater robotics, dexterous manipulation, and learning-enabled perception — always built and validated on real hardware.