Full list on Google Scholar ยท ORCID

Journal Articles
FibTac
FibTac: A Fiber-Based Pneumatic Gripper with Embodied Tactile Sensing
Sheeraz Athar, X. Zhang, M. R. I. Prince, V. G. Duffy, Yu She
npj Robotics, vol. 4, art. 47, Nature Portfolio, 2026
Nature Portfolio๐Ÿ… IROS 2026 Best Paper Finalist
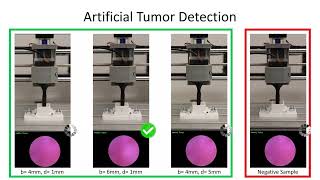
TacScope
TacScope: A Miniaturized Vision-Based Tactile Sensor for Surgical Applications
M. R. I. Prince, Sheeraz Athar, P. Zhou, Yu She
Advanced Robotics Research, Wiley, 2025
VibTac
VibTac: A High-Resolution, High-Bandwidth Tactile Sensing Finger for Multimodal Perception
Sheeraz Athar, X. Zhang, J. Ueda, Y. Zhao, Yu She
IEEE Transactions on Haptics, vol. 18, pp. 507โ€“518, 2025
๐Ÿฅˆ ASME MRC 2nd Prize
VisTac
VisTac: Towards a Unified Multimodal Sensing Finger for Robotic Manipulation
Sheeraz Athar, G. Patel, Z. Xu, Q. Qiu, Yu She
IEEE Sensors Journal, vol. 23, no. 20, pp. 25440โ€“25450, 2023
Conference Proceedings
IROS 2020
Vacuum-Driven Auxetic Switching Structure and Its Application on a Gripper and Quadruped
S. Liu, Sheeraz Athar, M. Y. Wang
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020
Patents
๐ŸŒŠ
Trimodal Underwater Robot: Integrated Drifting, Gliding, and Thrusting Platform
Sheeraz Athar, A. Patel, S. Shelar, C. Hillyer, N. Nguyen, V. Vivek, Yu She
Patent in preparation, Purdue University, 2026
โœ‹
FibTac: A Pneumatic Fiber-Based Tactile Gripper for Embodied Sensing and Manipulation
Sheeraz Athar, Yu She
Patent in preparation, 2025