 Play video
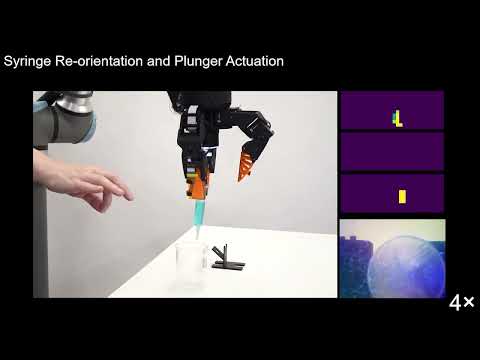
VTAP Gripper: Synergizing Fingertip Sensing and a Visuo-Tactile Active Palm for Dexterous In-Hand Manipulation
* Equal contribution
IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
Postdoctoral ResearcherPhysical AI & Robotics Initiative · University of Notre Dame
I'm a postdoctoral researcher in the Physical AI & Robotics (PAIR) Initiative at the University of Notre Dame, working with Prof. Nikolaus Correll. Previously, I was a Ph.D. student in the MARS Lab at Purdue University with Prof. Yu She. Before that, I earned an M.Phil. from HKUST with Prof. Michael Yu Wang and a B.Tech. from Aligarh Muslim University. I work on how robots can use touch and physical contact to perform dexterous tasks that remain difficult to automate. During my Ph.D., I developed multimodal tactile sensors for robotic manipulation, tactile sensing for robot-assisted minimally invasive surgery (RAMIS), and a multimodal underwater robot that drifts, glides, and thrusts. My current work focuses on dexterous robotic hands and humanoid robots that bring physical AI to challenging industrial applications.
Robots are moving out of structured factories into hospitals, oceans, and homes, where they must handle contact, uncertainty, and harsh conditions. My work connects three layers: sensors that capture rich physical information, soft and dexterous mechanisms that act on it, and complete systems tested in the field.
Hands and grippers that sense and adapt while they touch — from a visuo-tactile active palm to in-hand reorientation of syringes and millimeter-scale parts.VTAP Gripper · Notre Dame PAIR
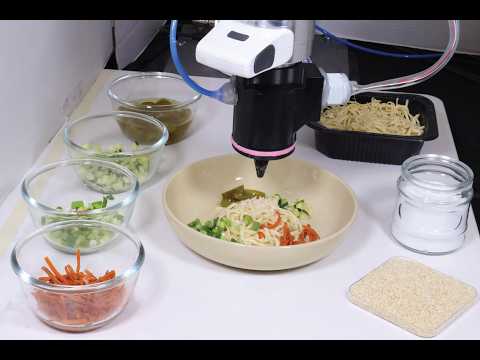
Fingertips that fuse geometry, force, vibration, and texture in one device.VisTac · VibTac · MuxGel

Fiber-embedded and auxetic structures that deform safely and sense as they move.FibTac
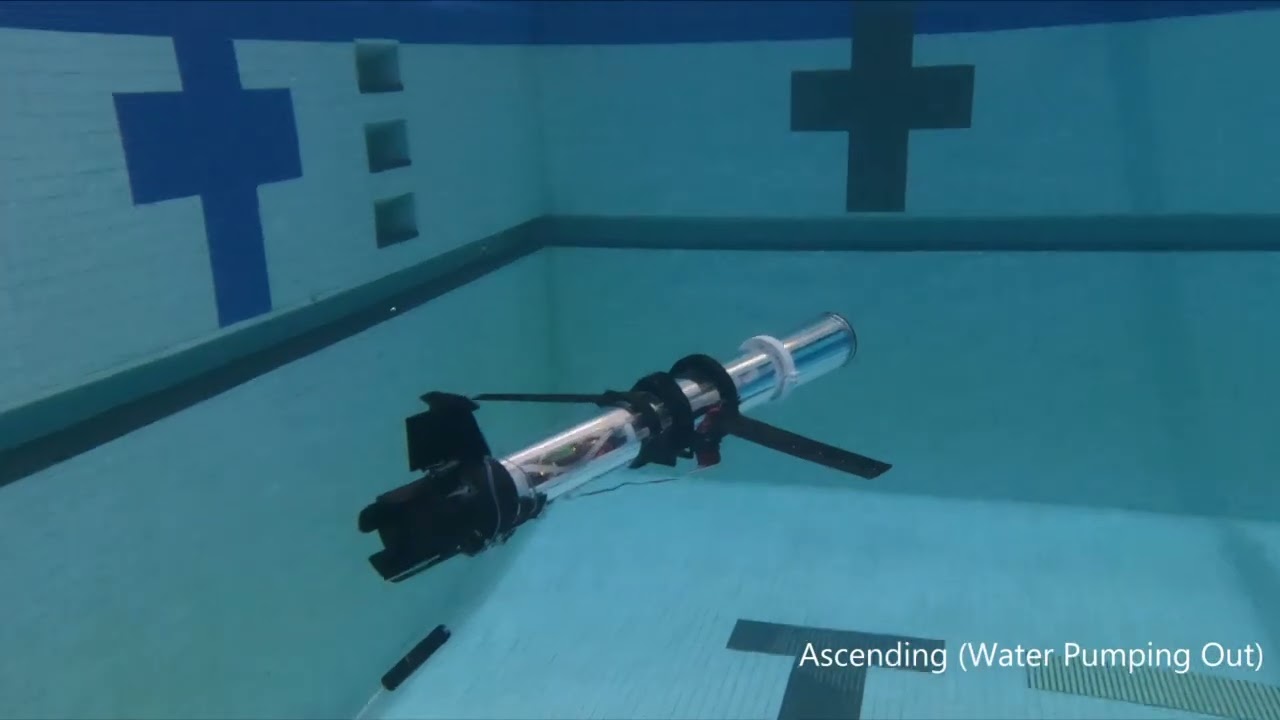
One robot that drifts, glides, and thrusts — built for long missions.Multimodal underwater robot
Millimeter-scale sensors that bring touch to minimally invasive surgery.TacScope · MVP-Tac
 Play video
* Equal contribution
IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
Play videonpj Robotics (Nature Portfolio), vol. 4, art. 47, 2026 · Open access
ASME International Design Engineering Technical Conferences, 2026 · NSF-funded
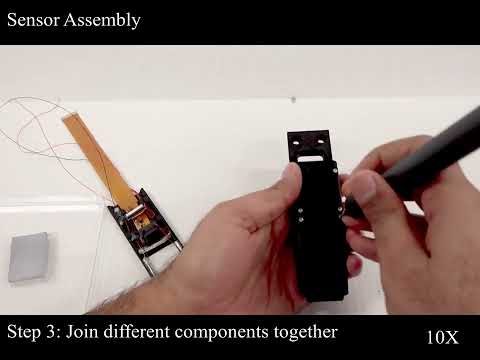 Play video
IEEE Transactions on Haptics, vol. 18, pp. 507–518, 2025
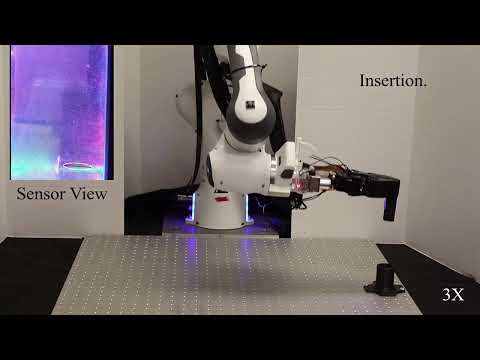 Play video
IEEE Sensors Journal, vol. 23, no. 20, pp. 25440–25450, 2023
Postdoctoral Researcher · PAIR Initiative with Prof. Nikolaus Correll
Ph.D., Industrial Engineering · MARS Lab with Prof. Yu She
M.Phil., Robotics · Cheng Kar-Shun Robotics Institute with Prof. Michael Yu Wang
B.E., Mechanical Engineering
I welcome inquiries about research collaborations, invited talks, and student mentorship.
sathar2@nd.edu →